InertiaX core Series
Inertial cores for navigation and flight-control integration, with triple-IMU array fusion, AHRS, time synchronization and multiple interfaces.
IMU600-V2
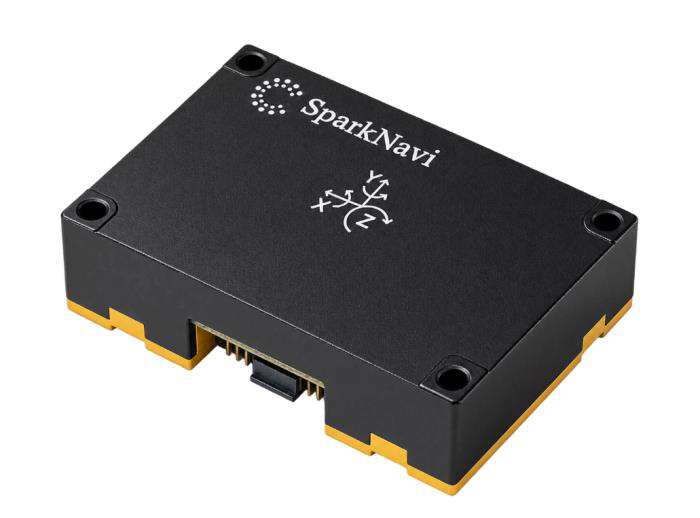
GNSS/INS Core · Triple-IMU Array Inertial Module
IMU600-V2 is the inertial core of SparkNavi InertiaX GNSS/INS systems. It combines three 6-axis MEMS IMUs and outputs fused angular rate, specific force, delta angle (Δθ) and delta velocity (Δv). Built-in AHRS, a barometer, GPS PPS time alignment and external triggering support system integration. The three IMUs are compared in real time; a faulty IMU can be excluded automatically without interrupting the output.
| Gyro ARW | Gyro bias instability | Accel bias instability | Max. IMU output |
|---|---|---|---|
| 0.015 °/√h | 0.35 °/h | 12 µg | 1000 Hz |
These are typical values from the datasheet, Preliminary Rev. 1.1 (October 2026), not guaranteed limits. See the product page for test conditions.
View product details & downloads
For samples, quotations or integration support, contact ethan@robotlab.com.tw